Dorsal RGB
A wrist-mounted camera observes the back of the hand and captures complementary motion and articulation cues.
Dual-View Wrist-Worn RGB–IMU Dataset for Dynamic Gesture Recognition
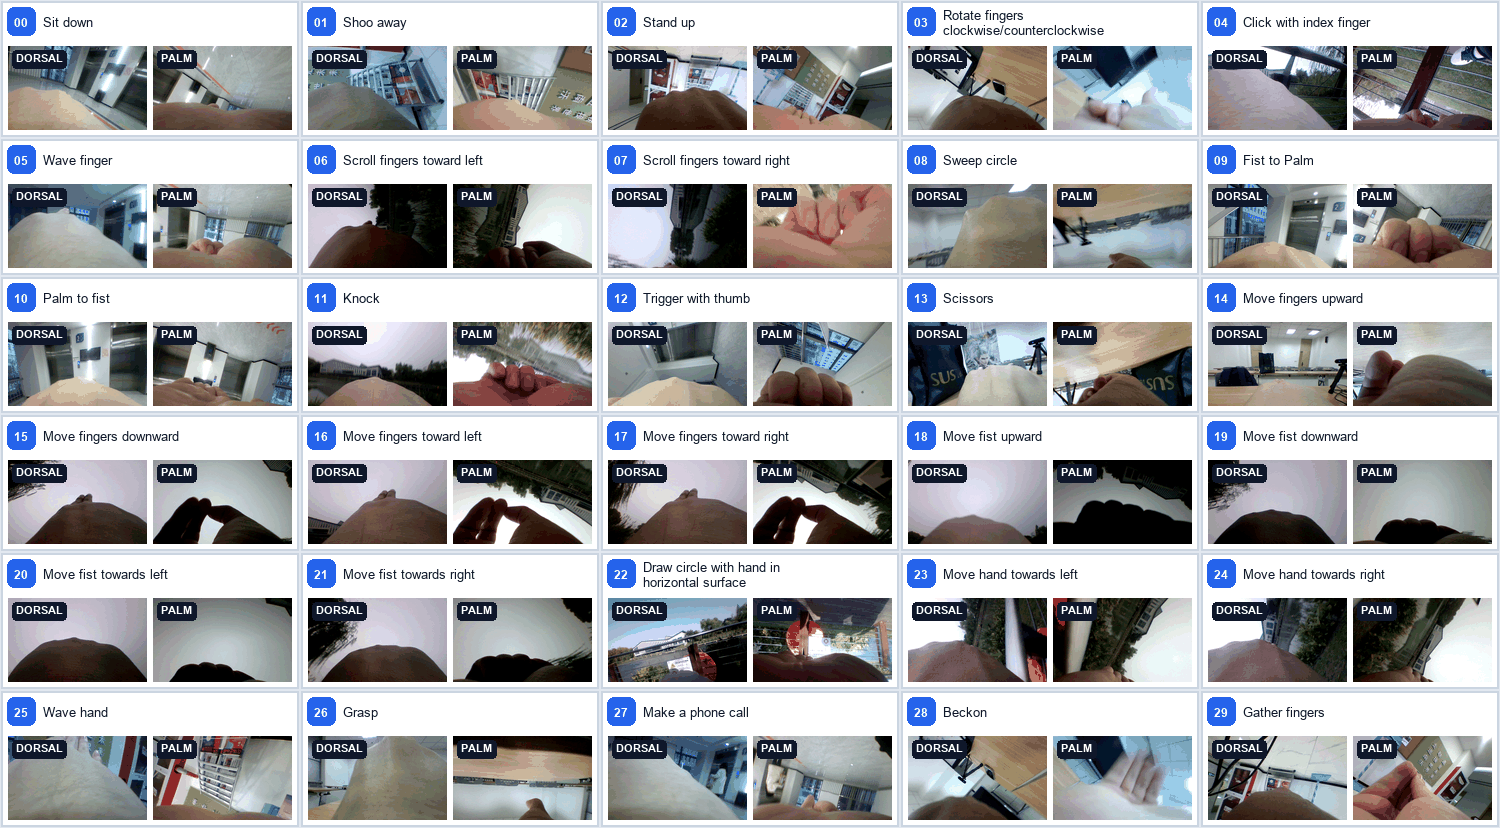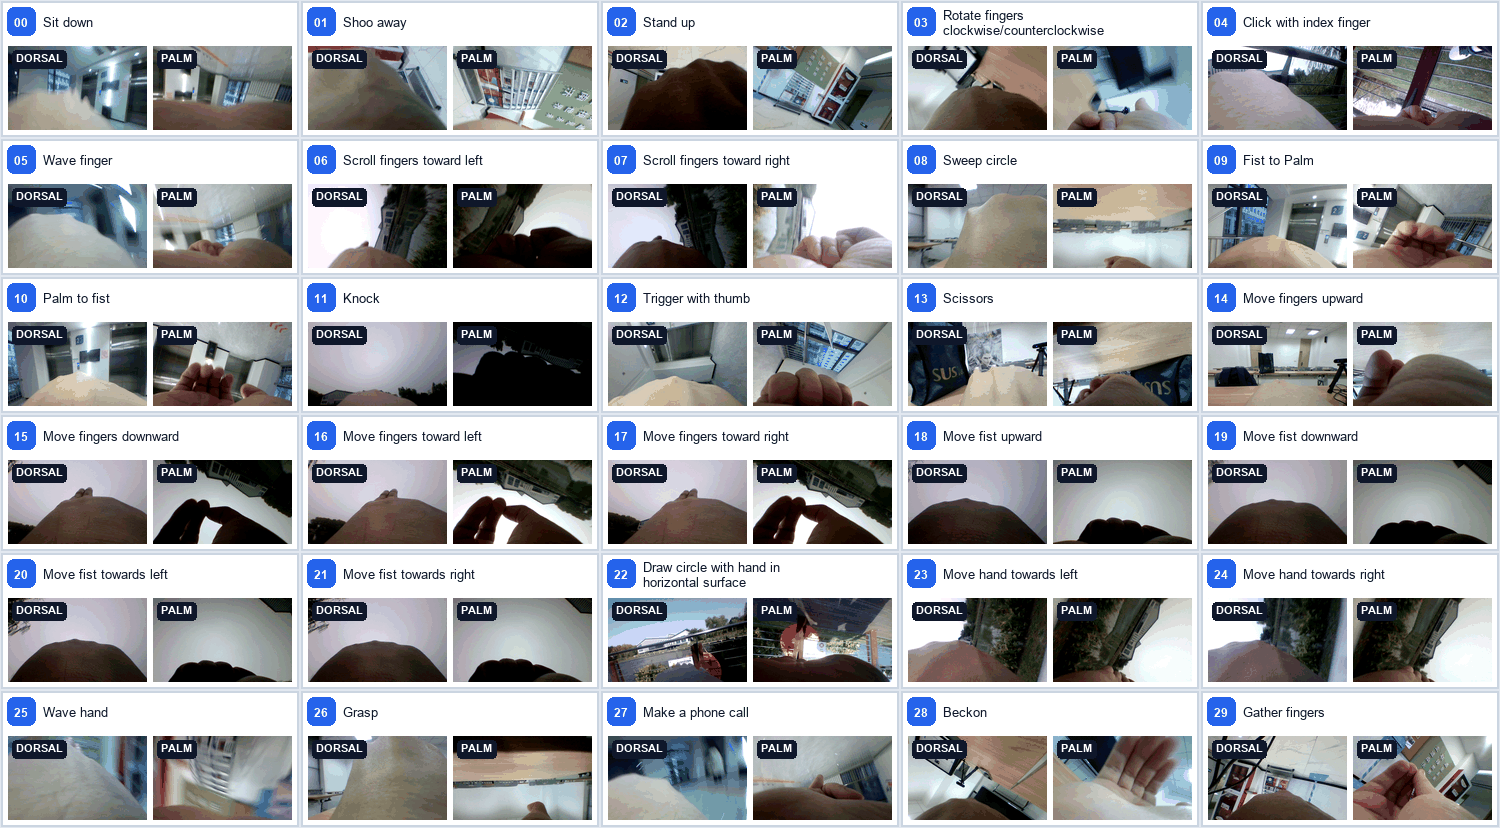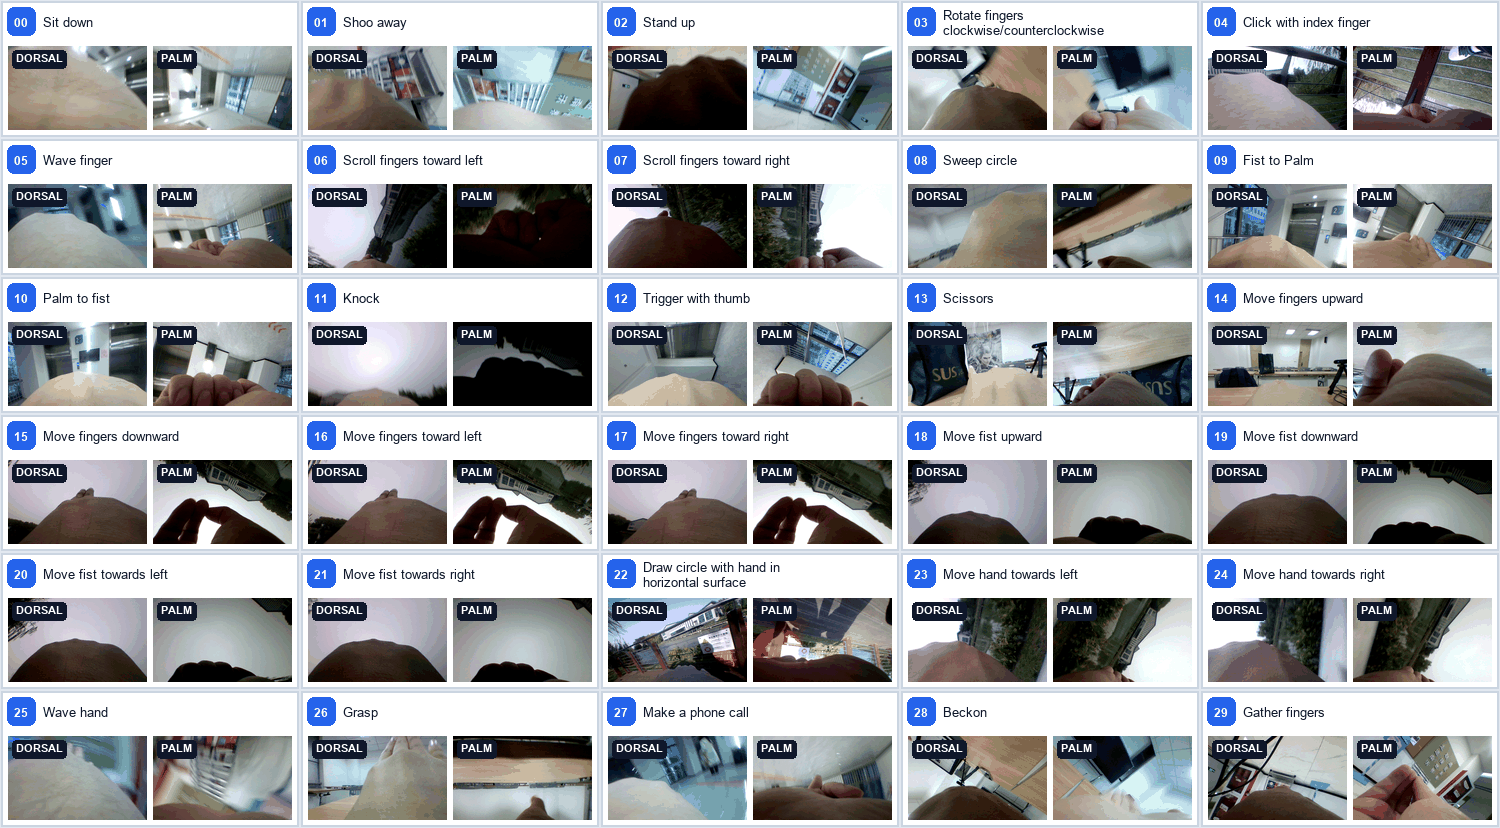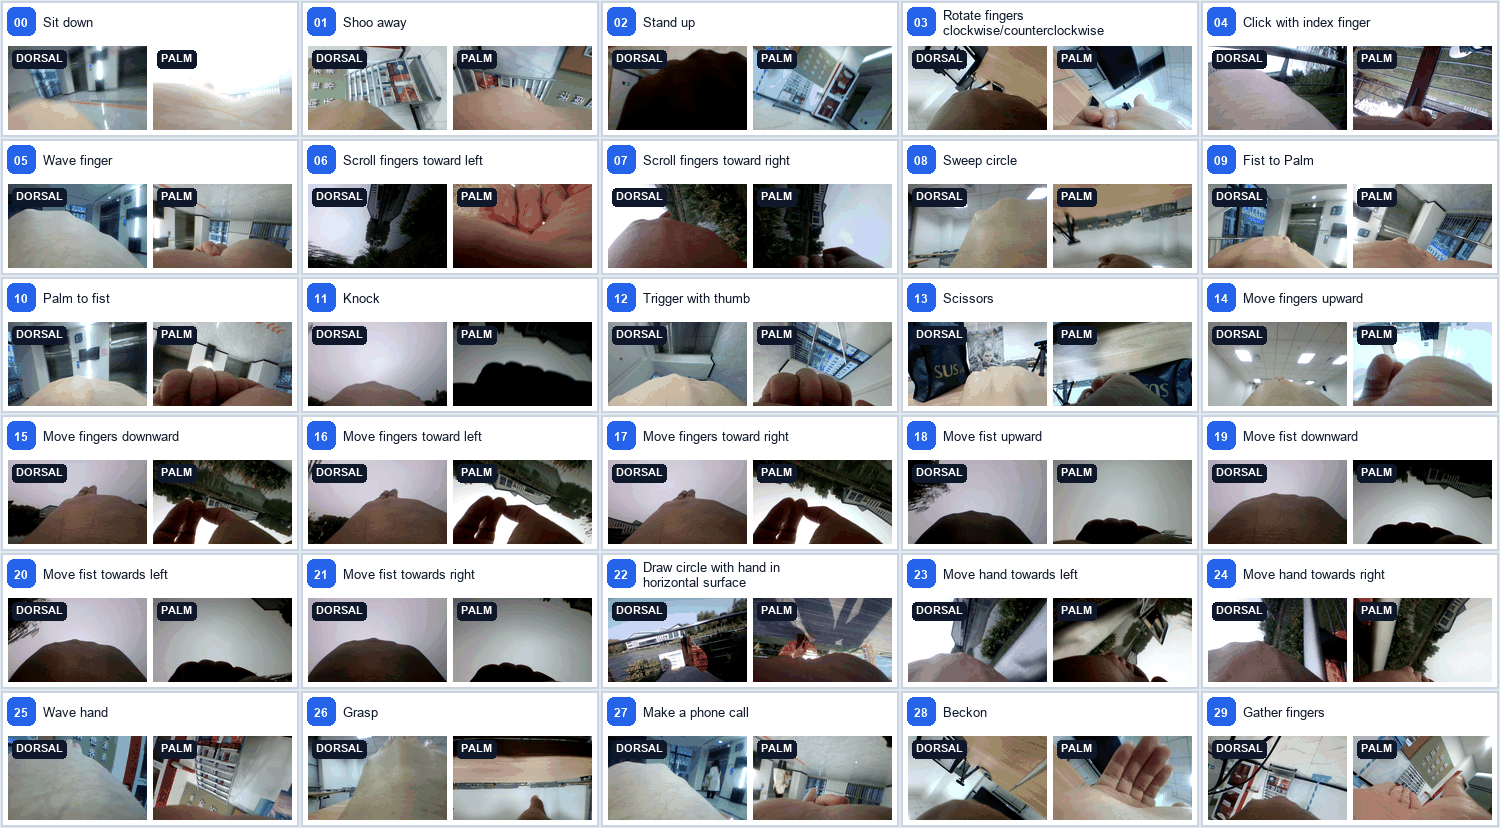
EgoWrist-Gesture30 captures complementary visual and inertial evidence for mobile, natural hand interaction.
Wrist-worn cameras enable always-available gesture input, but observe the hand from a moving and partially occluded viewpoint. EgoWrist-Gesture30 provides two complementary RGB streams oriented toward the dorsal and palm sides of the hand, together with WT61C-TTL inertial measurements. The dataset contains 30 dynamic gesture classes performed by 13 participants across 336 indoor and outdoor recordings. Canonical frame-level temporal annotations and balanced derived segments support gesture recognition, cross-user evaluation, reliability-aware multi-view learning, and multimodal sensor-fusion research.
A wrist-mounted camera observes the back of the hand and captures complementary motion and articulation cues.
A second wrist-mounted camera observes the palm side, reducing self-occlusion through a complementary viewpoint.
WT61C-TTL measurements provide acceleration, angular velocity, and Euler-angle signals for multimodal research.
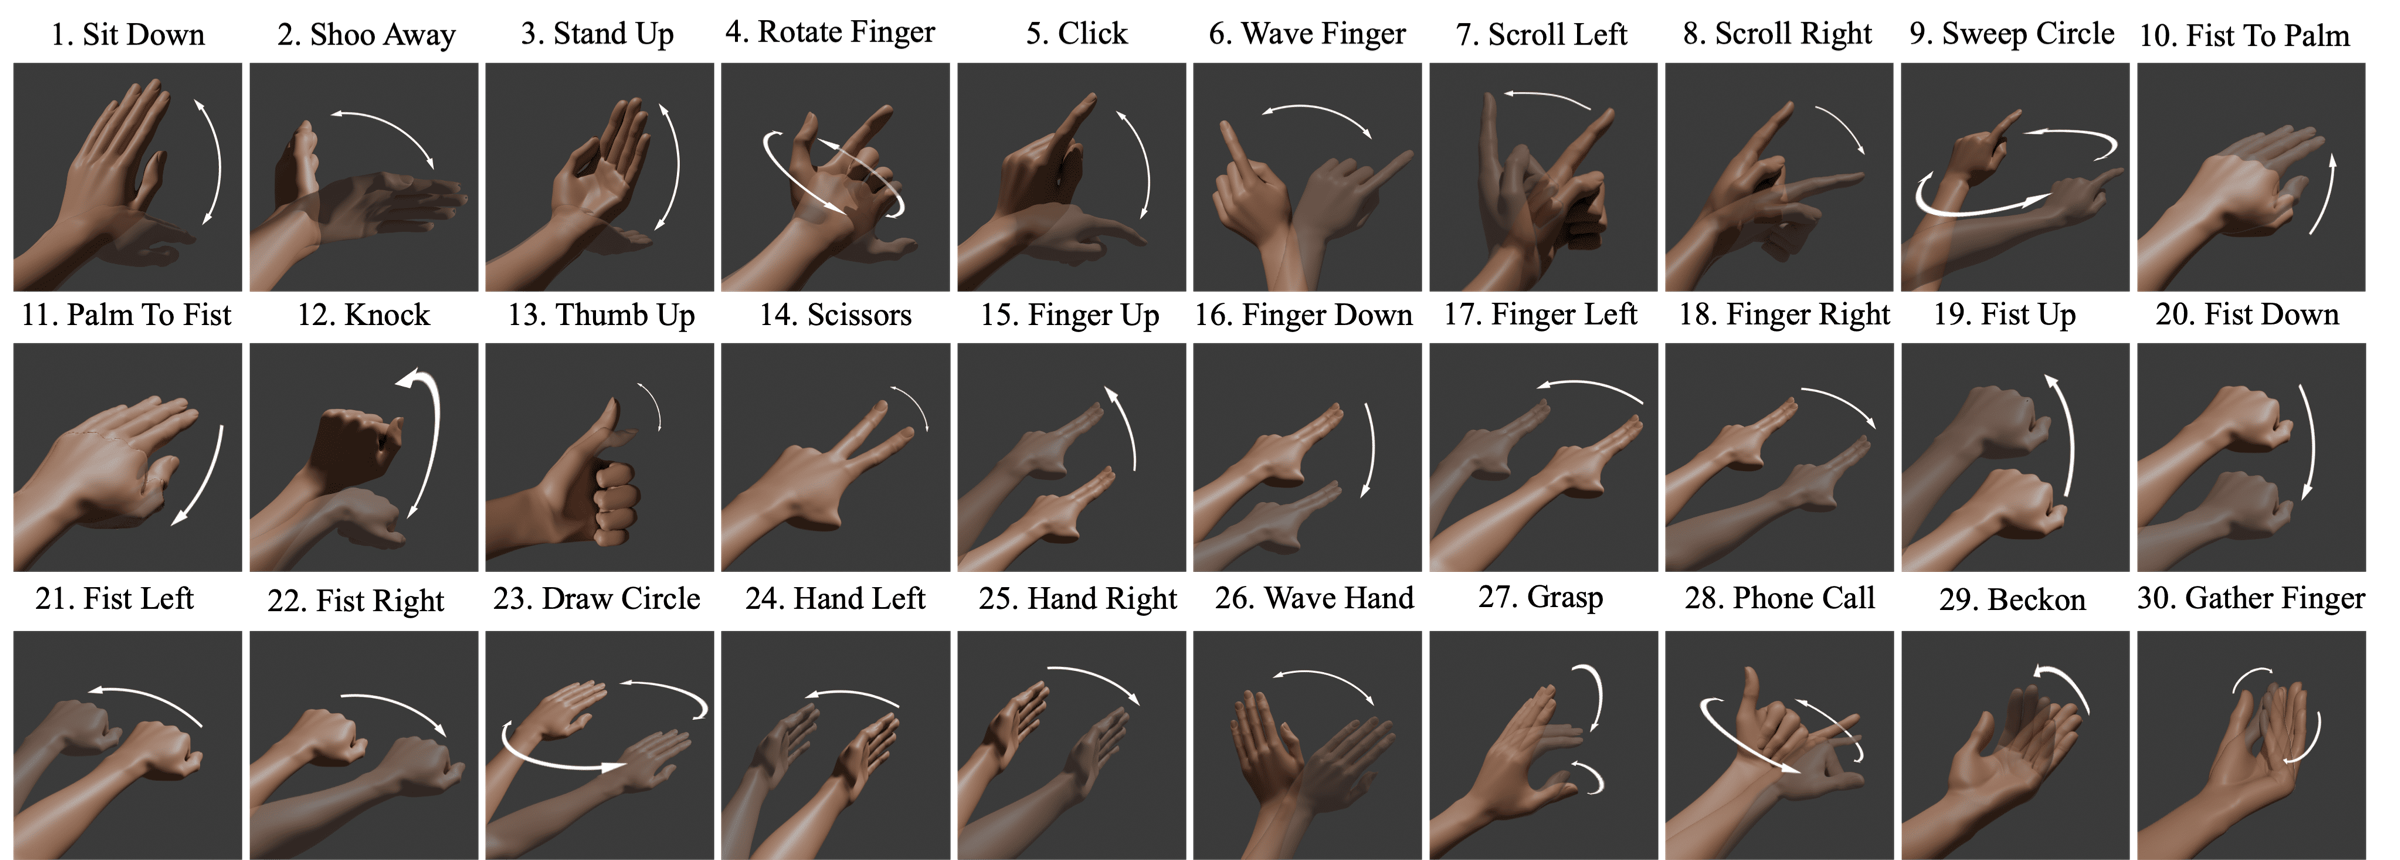
The vocabulary spans finger articulation, fist and palm transitions, directional motion, symbolic actions, and whole-hand gestures.
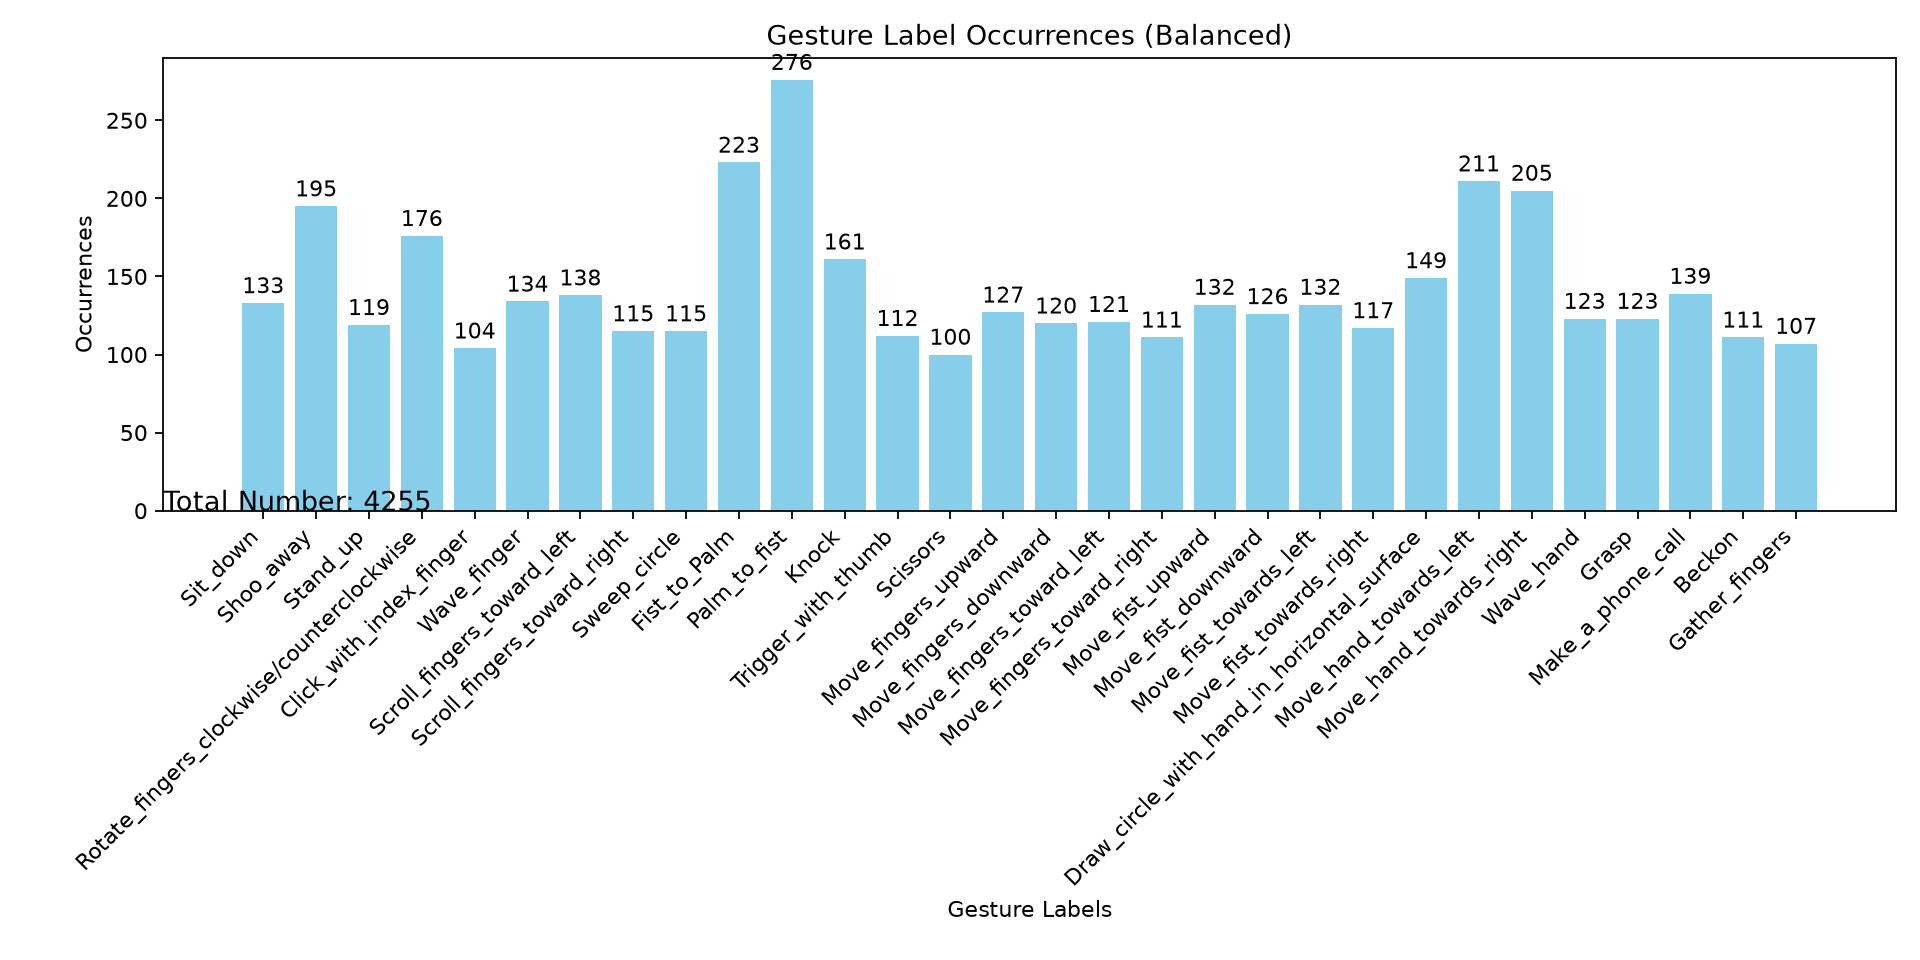
The balanced representation contains 4,255 temporal segments. Original intervals remain the canonical annotation source.
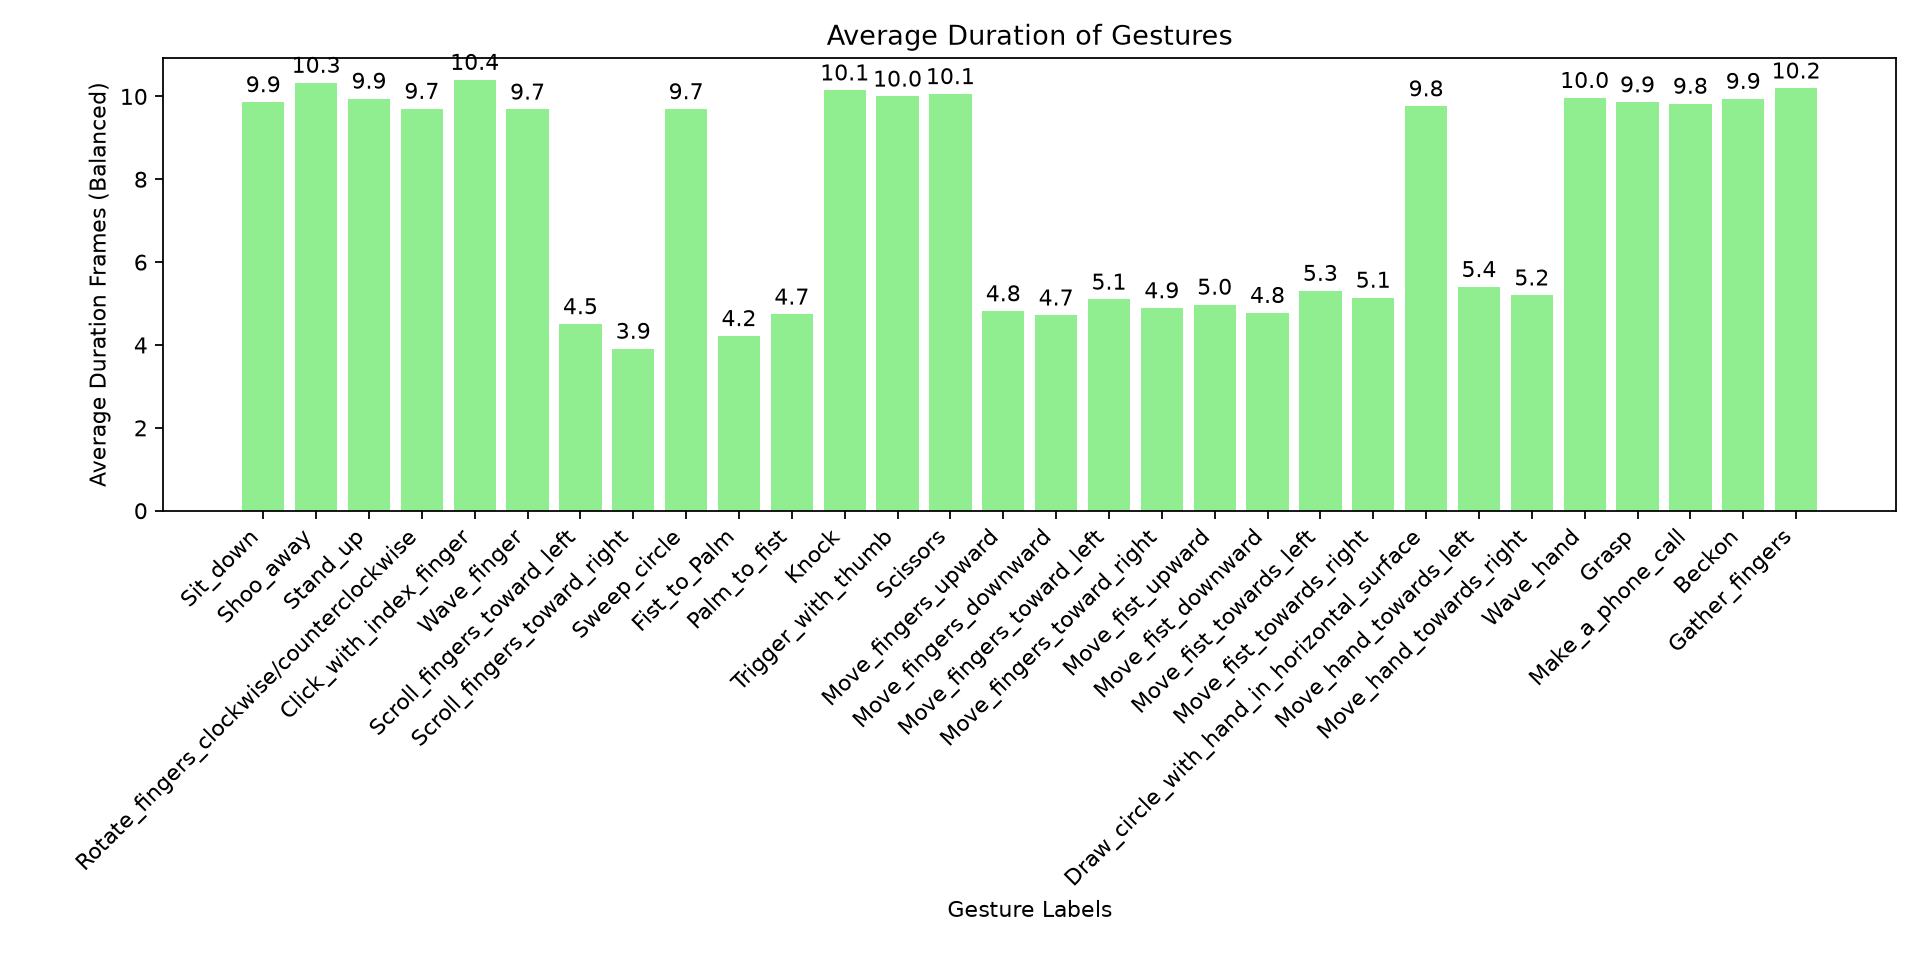
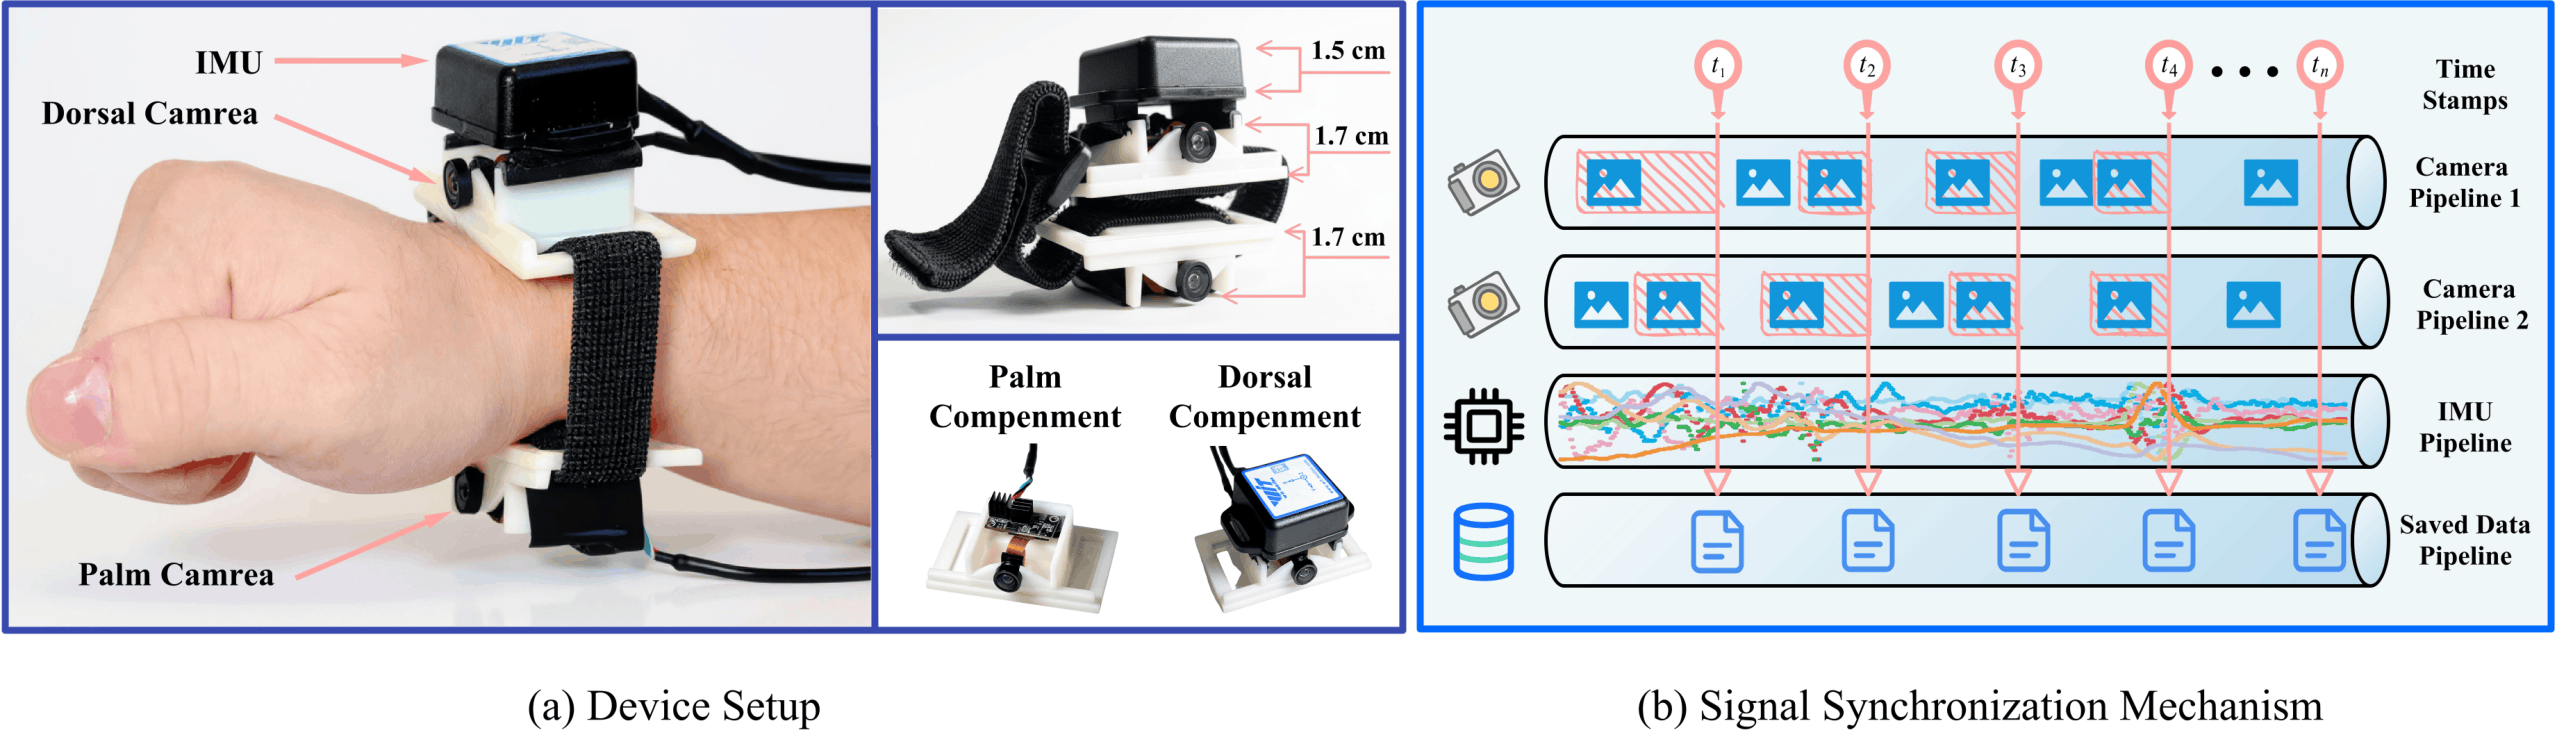
Two 160-degree fixed-focus cameras capture the dorsal and palm views at a nominal 12 FPS. A shared polling loop provides software-based approximate synchronization.
The GitHub repository hosts temporal annotations, acquisition software, processing utilities, quality-review tools, and integrity validators. Recorded RGB and IMU data are distributed separately.
subjectXX/
└── sceneY/
    └── recording_id/
        ├── dorsal/
        │   ├── 0.jpg
        │   └── ...
        ├── palm/
        │   ├── 0.jpg
        │   └── ...
        └── sensor/
└── sensor.csvEach recording CSV stores begin, end, and zero-based label fields. Both frame boundaries are inclusive.
14,27,1014 frames · class 10The release does not impose training, validation, or test partitions. Participant-disjoint protocols are recommended for cross-user evaluation.
Annotations and research tools are versioned on GitHub. Submit the access request form for the separately distributed recorded RGB and IMU data.
Canonical per-recording CSV files and aggregate JSON representations for all 30 classes.
Browse annotations →Dorsal RGB, palm RGB, and WT61C-TTL measurements are available by request for non-commercial academic and scientific research.
Request access →Multimodal acquisition, annotation processing, visualization, review, and validation utilities.
Browse tools →UNDER PEER REVIEW
Peizhe Zhao, Zhenyang Gong, Ye Tao, Rui Shi, Nenglun Chen, Yang Zhang, Peibei Cao, Zhenglong Ding, Feng Jiang
The paper introduces a dual-view recognition framework that combines hierarchical feature extraction, biomechanical prototype manifold projection, and Bayesian confidence filtering for reliable wrist-worn gesture recognition.
Please cite the accompanying submission when using EgoWrist-Gesture30 in academic work.
@unpublished{zhao2026egowrist,
  title  = {EgoWrist: Reliability-Aware and
            Biomechanically Grounded Dynamic
            Gesture Recognition},
  author = {Zhao, Peizhe and Gong, Zhenyang and
            Tao, Ye and Shi, Rui and Chen, Nenglun and
            Zhang, Yang and Cao, Peibei and
            Ding, Zhenglong and Jiang, Feng},
  year   = {2026},
  note   = {Manuscript under peer review}
}